01
Holding position without GPS
A downward-facing optical-flow sensor tracks ground texture to measure drift, and a rangefinder holds altitude, so the drone can hover in place indoors.
A small indoor drone that holds position and follows a subject without GPS.
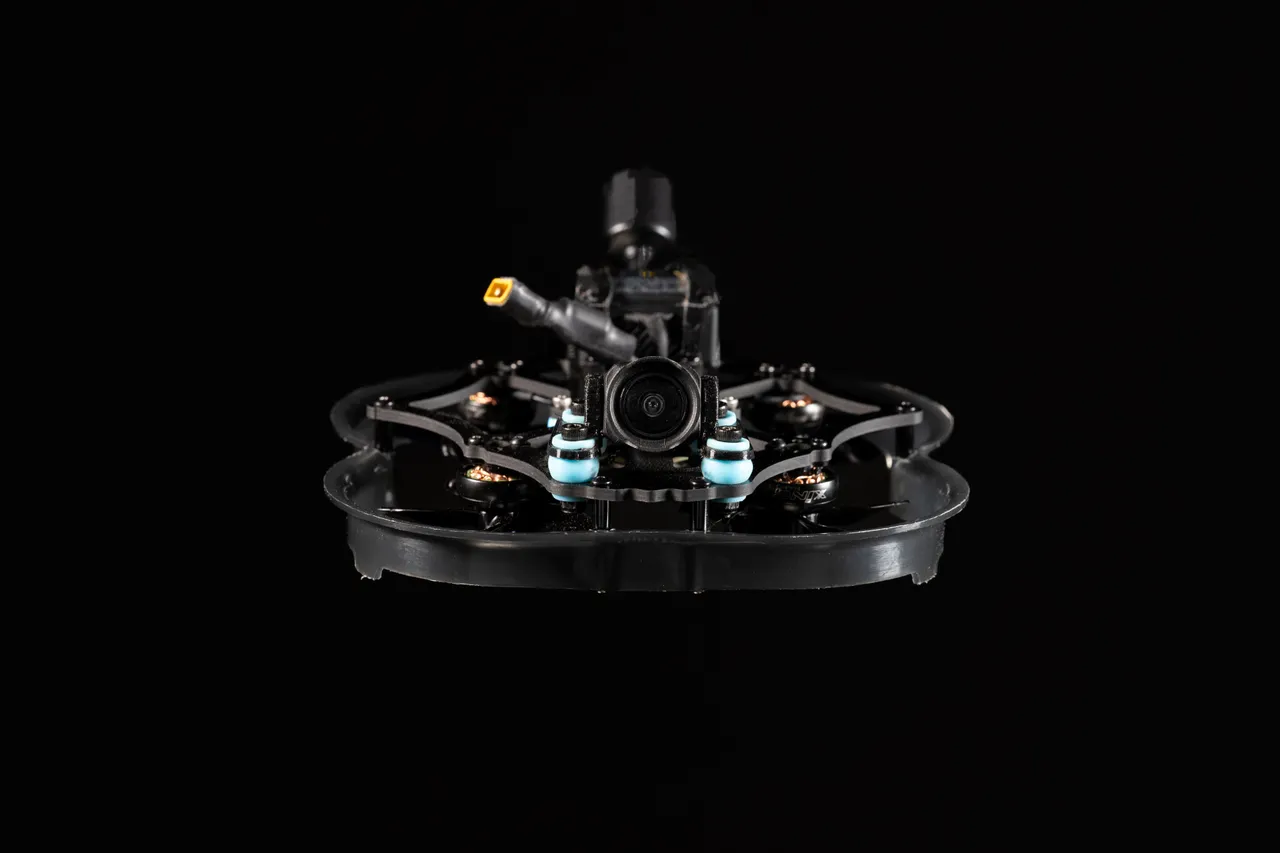
Indoors there's no GPS to hold position. I built a guarded micro-quad that uses optical flow and a rangefinder to hover in place, plus an onboard companion computer running vision-based tracking to follow a target.
A downward-facing optical-flow sensor tracks ground texture to measure drift, and a rangefinder holds altitude, so the drone can hover in place indoors.
A companion computer runs the tracking: it finds the target in the camera feed and sends position commands to the flight controller to keep it in frame.